
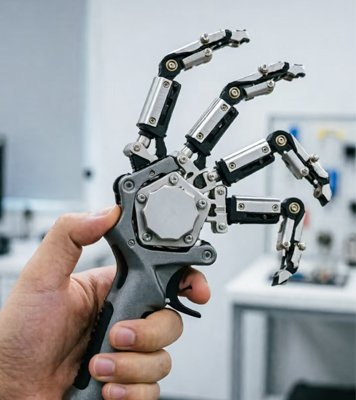
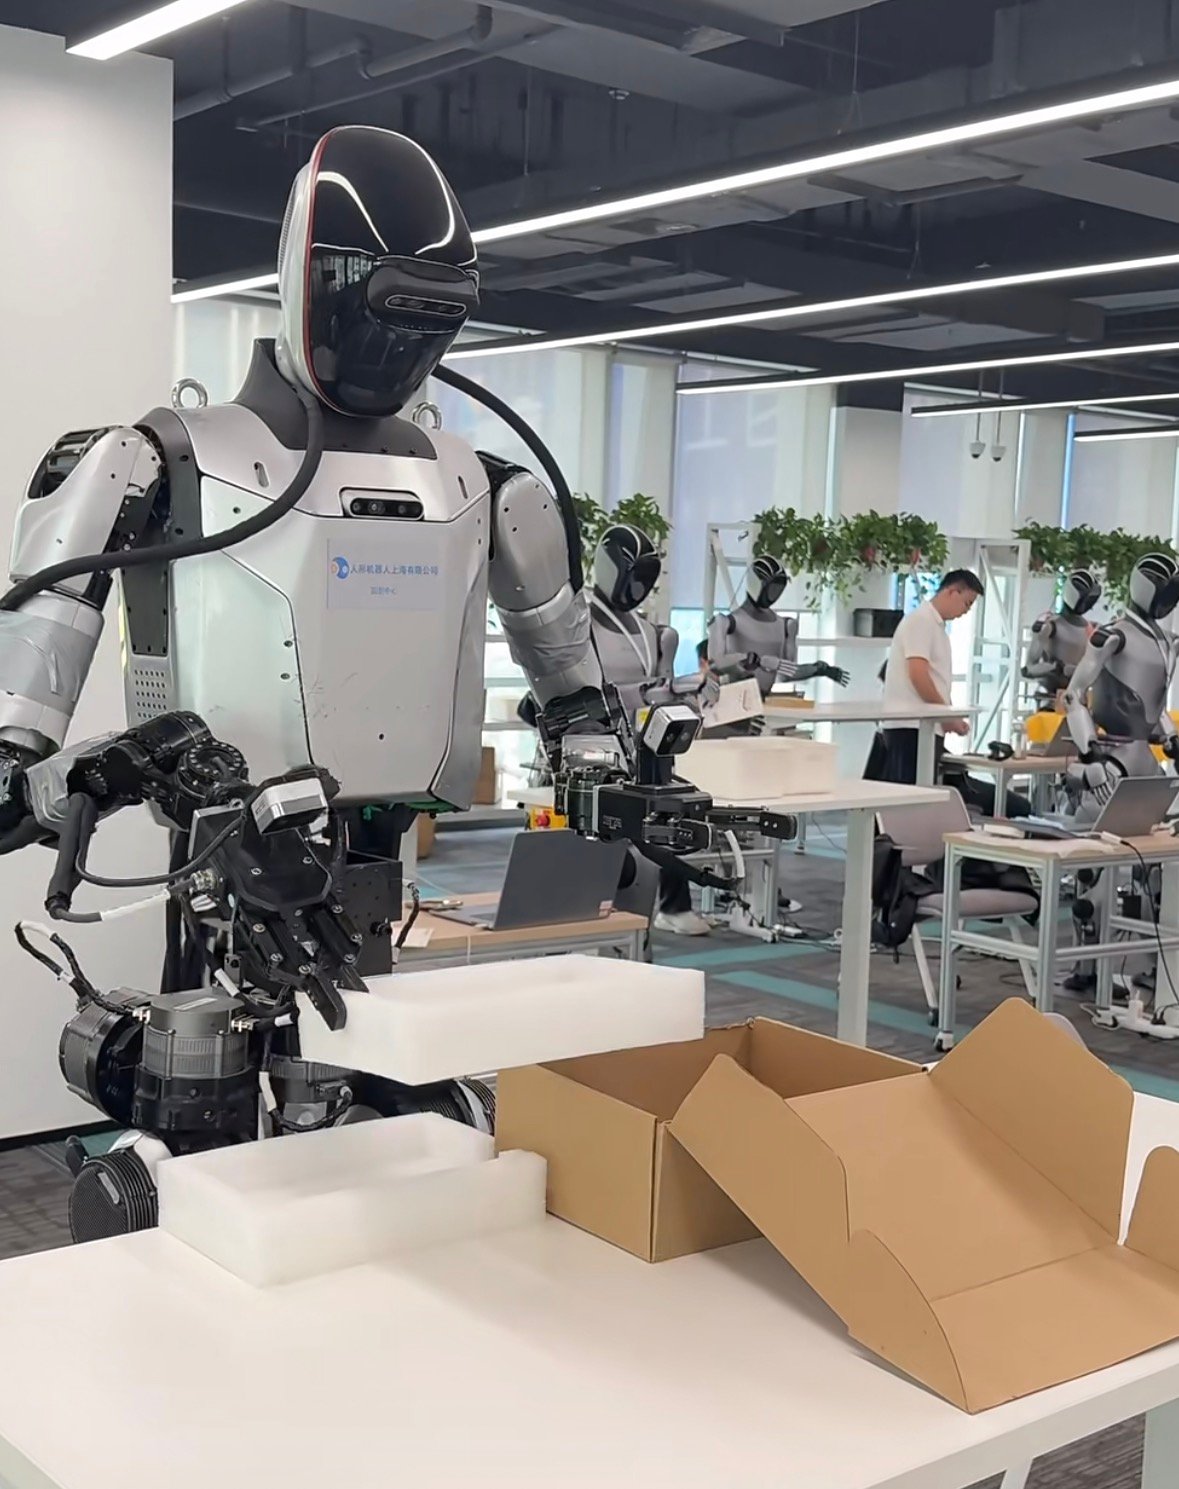
We deliver high-quality teleoperation data collection for robot learning, capturing synchronized observations, operator commands, robot states, gripper actions, and task outcomes from real-world manipulation episodes.
What We Capture
Multi-View RGB and RGB-D Video
Robot Joint and End-Effector States
Operator Commands and Action Signals
Gripper, Force and Tactile Signals
Object and Environment Context
Task Segments and Outcome Labels
97%
Valid Episode Yield
Through calibrated hardware, standardized task protocols, and multi-stage quality control.Production-Grade Teleoperation Data for Robot Learning
100%
Action-Observation Alignment
Robot states, operator commands, sensor observations, and task outcomes aligned in every trajectory.Why Choose Our Teleoperation Data Collection Service?
Robotics Integration Expertise
Our teams understand robot control stacks, observation and action spaces, timing, calibration, safety constraints, and trajectory quality.
Custom Task Engineering
We tailor task definitions, workcells, objects, difficulty levels, operator procedures, and acceptance criteria to your robot and model.
Trajectory Quality Control
Automated checks and human review detect latency, discontinuities, unsafe actions, incomplete episodes, and inconsistent task execution.
Scalable Collection Operations
We coordinate hardware, operators, environments, schedules, maintenance, and secure data delivery from pilot to production scale.