
The Embodied AI Data Bottleneck: Why More Hours Are Not Enough
Embodied AI does not suffer from a shortage of video alone. The real bottleneck is...
Read More

UMI vs Teleoperation vs Egocentric Data: How to Choose the Right Collection Method
A practical decision guide for choosing direct robot teleoperation, UMI-style demonstrations, egocentric capture—or a designed...
Read More
Multimodal Synchronization for Robot Learning: The Hidden Label in Every Demonstration
Why time alignment functions like a hidden label in robot demonstrations, and how to design,...
Read More
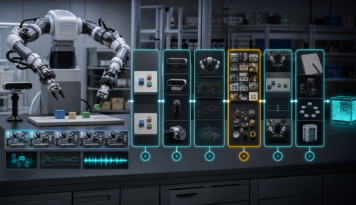
What Makes Robot Demonstration Data Training-Ready? A Practical Acceptance Framework
Use the TRACED framework—Task, Recording, Action-state, Coverage, Episode and Documentation—to define acceptance for robot demonstration...
Read More
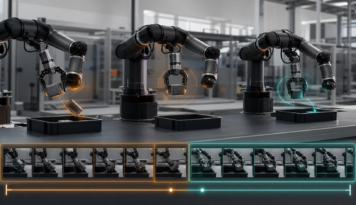
Failure and Recovery Data: The Missing Half of Robot Learning Datasets
How to capture, classify and use robot failures, interventions and recovery trajectories without contaminating the...
Read More
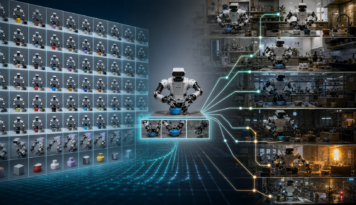
From Simulation to the Long Tail: Designing Real-World Robot Data That Generalizes
A practical framework for combining simulation, human demonstrations and targeted real-world robot data to cover...
Read More
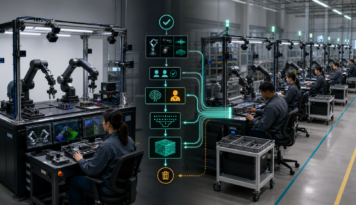
How to Scope an Embodied AI Data Collection Pilot That Can Scale
Use the SCOPE framework to validate task definitions, capture interfaces, coverage, quality controls and unit...
Read More